Reconstruction-Driven Reinforcement Learning For Autonomous Satellite Inspection With Gaussian Splatting
Abstract
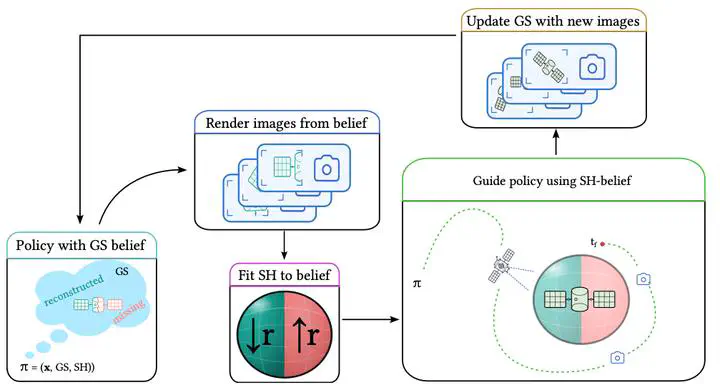
Recent work in reinforcement learning policies for spacecraft inspection has focused on optimizing coverage of a discretized spherical approximation of the target, even though the desired inspection product is an accurate geometric model. This separation between the planning objective and the reconstruction product can reward observations that add little information while excluding views that remain useful for recovering poorly reconstructed geometry. We investigate whether cou- pling reinforcement learning with an active active reconstruction method can overcome these challenges by incorporating a global geometry approximation into the optimization process. We propose Splat-RL, a reinforcement-learning framework that derives its observation and image-capture reward from the reconstruction error of a Gaussian Splatting model. We compare Splat-RL with an illumination- aware coverage policy using this spherical heuristic. We find that the coverage policy fails to discover full geometric detail because its spherical spacecraft approximation neglects complex shadowing effects, whereas Splat-RL selects high- illumination and informative views that reconstruct the missing structure and im- prove all reported three-dimensional reconstruction metrics in our experiments. These results show that the accurate photometric information produced by a GS model can be combined with RL approaches to reliably find better inspection tra- jectories compared to current coverage based spherical heuristic models.